I am currently a postdoctoral researcher at the School of Geodesy and Geomatics, Wuhan University, working with Prof. Yibin Yao. My research interests include 3D computer vision, embodied intelligence, multi-sensor fusion, and Global Navigation Satellite System (GNSS) localization. I was also a research intern at JD.com, Inc. I received my Bachelor’s degree from China University of Geosciences (Beijing) in 2018, and my Master’s and Ph.D. degrees from Wuhan University in 2021 and 2025, respectively, under the supervision of Prof. Jiancheng Li.
News
🚀 [09.2026] One paper is accepted by Satellite Navigation!
🚀 [04.2026] One paper is accepted at ICLR 2026 as an Oral!
🚀 [01.2026] One paper is accepted by IEEE Transactions on Robotics (T-RO)!
🚀 [12.2024] Reached 100+ citations milestone on Google Scholar
🚀 [07.2024] One paper URS-NeRF is accepted at ECCV 2024
😎 [10.2023] Joined CVRP Lab of NUS as a visiting student supervised by Gim Hee Lee!
🚀 [06.2023] One paper DRT-VIO is CVPR 2023!
🚀 [06.2022] One paper EDM Method is accepted at GPS Solutions!
🚀 [01.2022] One paper PLS-VIO is accepted at ICRA 2022 & RAL!
Featured Works
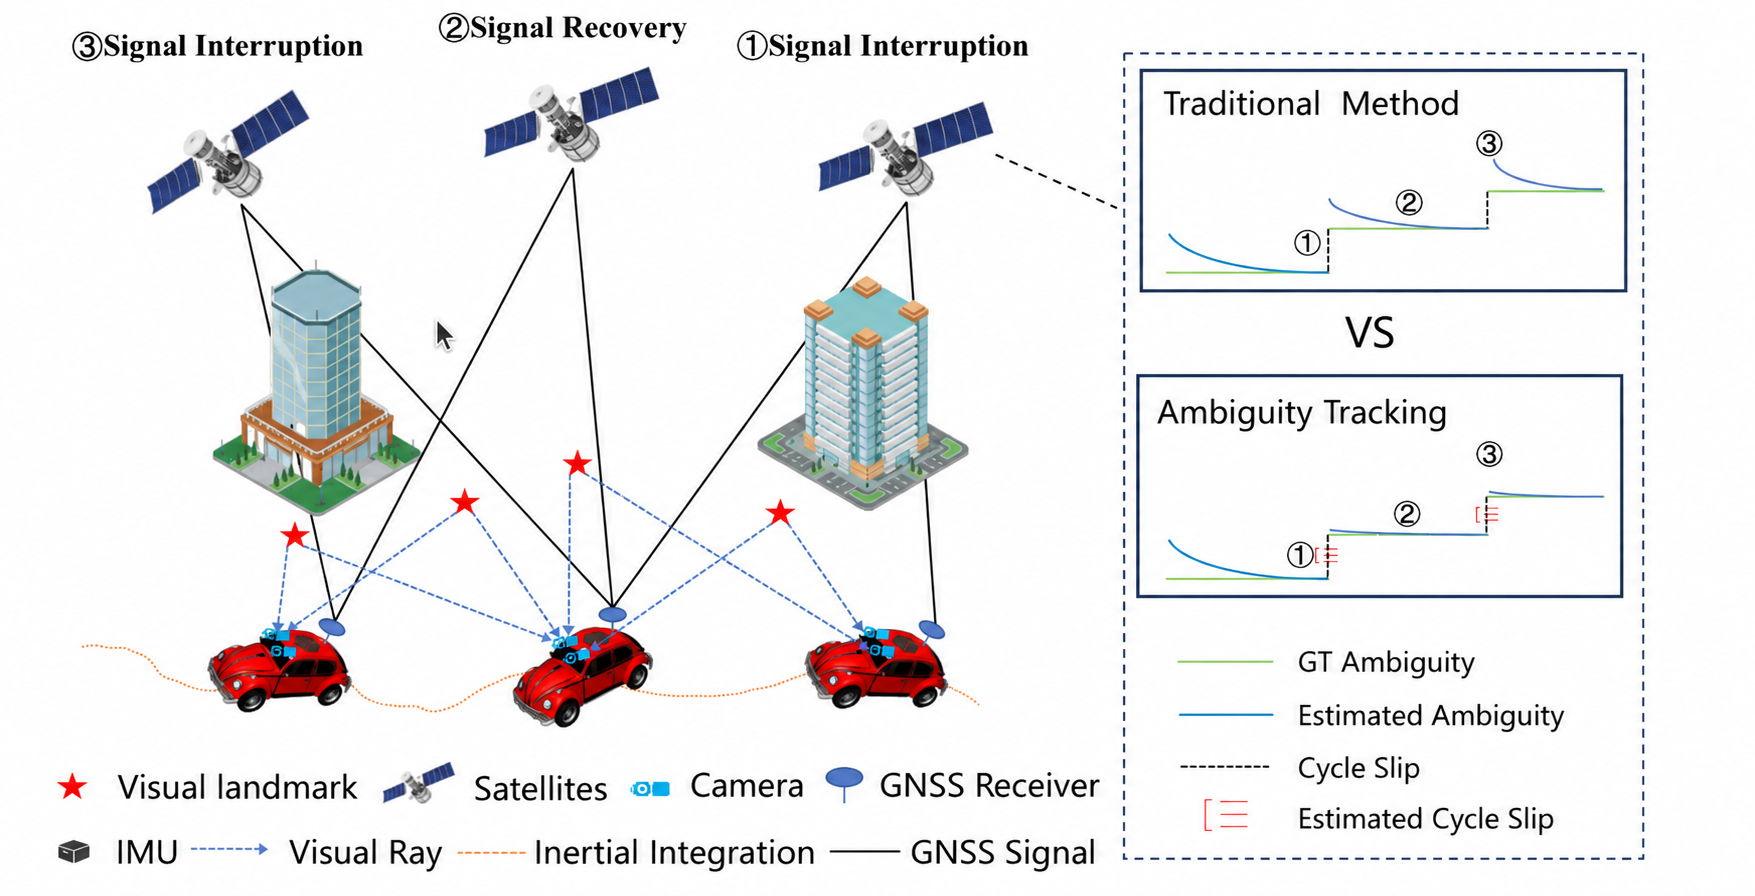
A Cross-epoch Ambiguity Tracking Method for GNSS/INS/Vision Urban Navigation
Bo Xu, Shoujian Zhang, Yibin Yao, Xingxing Li, Jingrong Wang, Shengyu Li
Satellite Navigation, 2026 (Accepted)

Vid-LLM: A Compact Video-based 3D Multimodal LLM with Reconstruction-Reasoning Synergy
Haijier Chen*, Bo Xu*, Shoujian Zhang, Haoze Liu, Jiaxuan Lin, Jingrong Wang
ICLR, 2026 (Oral)
[Project Page] [PDF] [Code]
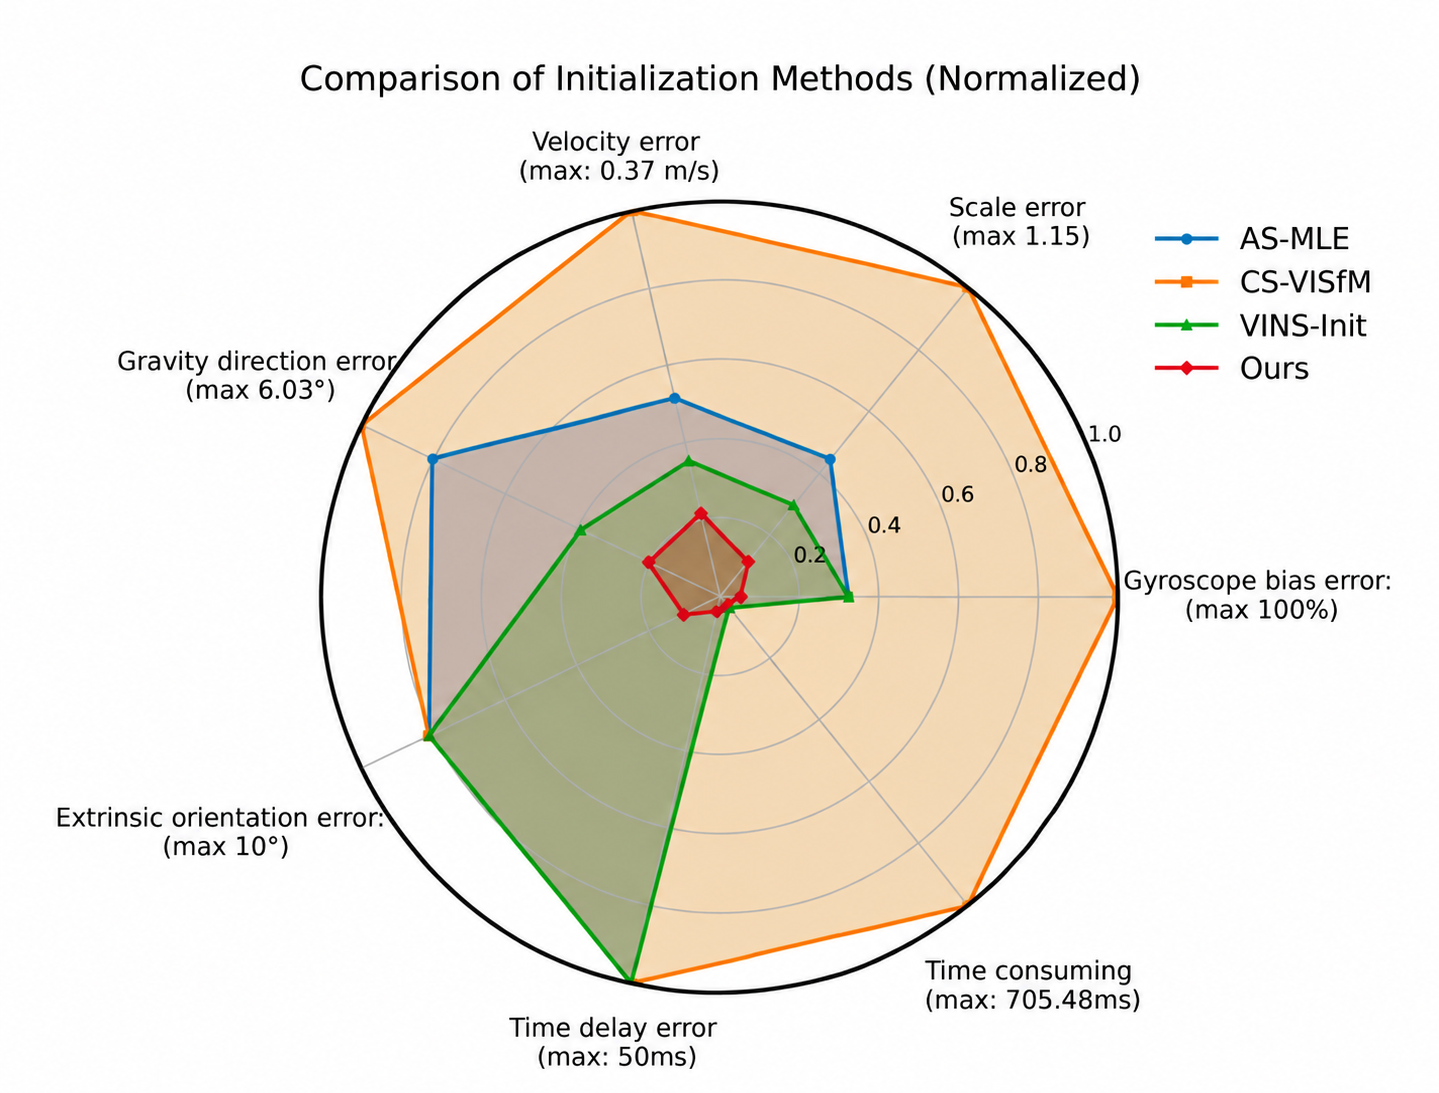
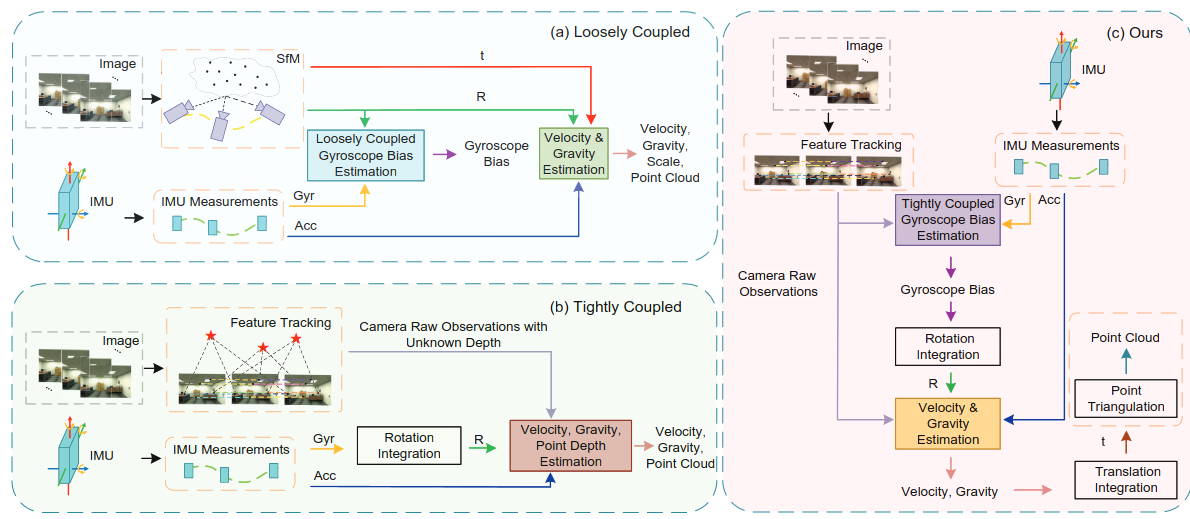
A Rotation-Translation Decoupled Solution for Visual-Inertial Initialization and Online Spatial-Temporal Calibration
Bo Xu*, Zewen Xu*, Yijia He, Zhanpeng Ouyang, Hao Wei, Yihong Wu, Jiancheng Li, Hongdong Li
IEEE Transactions on Robotics (T-RO), 2026
[Paper] [Code]
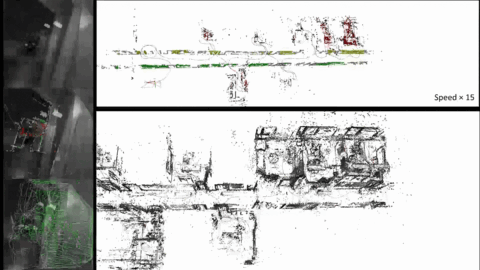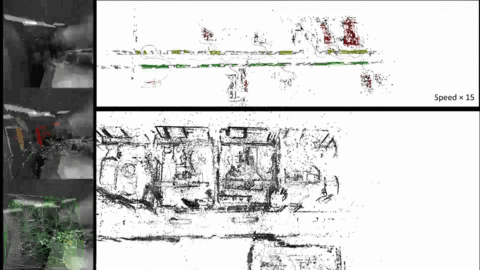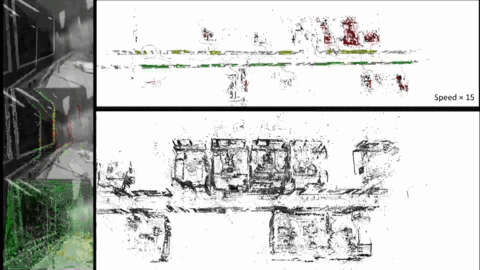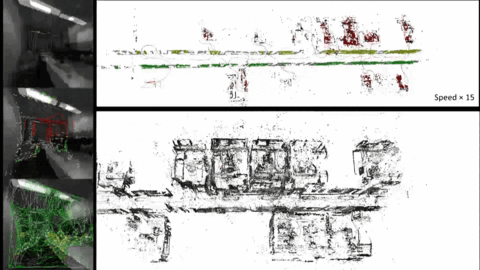
PVI-DSO: Leveraging Planar Regularities for Direct Sparse Visual-Inertial Odometry
Bo Xu, Xin Li, Jingrong Wang, Chau Yue, Jiancheng Li,
IEEE Sensors Journal
[Code] [PDF]
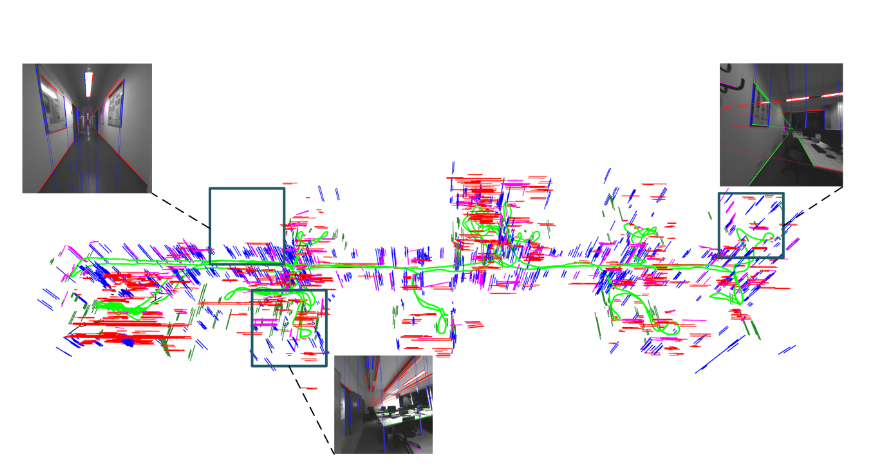
Leveraging Structural Information to Improve Point Line Visual-Inertial Odometry
Bo Xu, Peng Wang, Yijia He, Yu Chen, Yongnan Chen, Ming Zhou,
ICRA 2022 & RAL
[Code] [PDF]
Other Publications / Preprints
Mingyue Liu, Shoujian Zhang, Bo Xu, Jingrong Wang, Huizhong Zhu, Xinchao Xu GNSS/Vision/INS tight integration navigation and positioning method based on feature enhancement in low-light environments. Measurement Science and Technology, 2026.
Li Yan, Yinghao Zhao, Jicheng Dai, Bo Xu, Hong Xie, Yuquan Zhou Intelligent perception measurement technology of autonomous UAV for unknown environment . Acta Geodaetica et Cartographica Sinica (测绘学报).
Yu Chen, Bo Xu, Bin Wang, Jiaming Na, Pei Yang GNSS Reconstrainted Visual–Inertial Odometry System Using Factor Graphs. IEEE Geoscience and Remote Sensing Letters.
Jingrong Wang, Jingnan Liu, Shoujian Zhang, Bo Xu, Yarong Luo and Ronghe Jin Sky-view images aided NLOS detection and suppression for tightly coupled GNSS/INS system in urban canyon areas. Measurement Science and Technology.
Bo Xu, Shoujian Zhang, Jingrong Wang, Jiancheng Li An innovation-based cycle-slip, multipath estimation, detection and mitigation method for tightly coupled GNSS/INS/Vision navigation in urban areas. ArXiv.
Jingrong Wang, Bo Xu, Ronghe Jin, Shoujian Zhang, Kefu Gao, Jingnan Liu Sky-GVIO: an enhanced GNSS/INS/Vision navigation with FCN-based sky-segmentation in urban canyon. ArXiv.
Zewen Xu, Yijia He, Hao Wei, Bo Xu, BinJian Xie, Yihong Wu An Accurate and Real-time Relative Pose Estimation from Triple Point-line Images by Decoupling Rotation and Translation. ArXiv.